Cambridge IGCSE Additional Mathematics 0606 Topic 14 develops differentiation and integration across algebraic, trigonometric, exponential and logarithmic functions. It applies calculus to gradients, stationary points, connected rates, approximations, optimisation, plane areas and straight-line kinematics. No calculus formulas are supplied, first-principles differentiation is not required, and points of inflexion are excluded.
1. Derived functions and limits
The derivative measures instantaneous rate of change and graph gradient. Cambridge expects only an informal limit idea: as an increment δx approaches zero, the secant gradient approaches the tangent gradient. Differentiation from first principles is explicitly not required.
Required notation includes f'(x), f''(x), dy/dx, d²y/dx², δx and δx approaching zero. Interpret first and second derivatives in context rather than treating them only as symbols.
2. Standard derivatives
Candidates know derivatives of xⁿ for any rational n, sin x, cos x, tan x, eˣ and ln x. Trigonometric differentiation always uses radians.
The power rule gives d/dx(xⁿ) = nxn−1. Constant multiples and sums differentiate term by term. Standard trigonometric results are:
derivative of sin x is cos x;
derivative of cos x is -sin x;
derivative of tan x is sec²x.
The derivative of eˣ is eˣ, and derivative of ln x is 1/x for x > 0.
3. Chain, product and quotient rules
For a composite f(g(x)), multiply the outer derivative by the inner derivative. Keep the inner expression visible until the chain factor is included.
Check this topic from memory
Attempt the matching topic bank before reopening the notes. Use each missed idea to decide what to review next.
For product uv, derivative is u'v + uv'. For quotient u/v, derivative is (u'v - uv')/v². Bracket the entire numerator and preserve the original denominator restrictions.
Choose algebraic simplification before differentiating when it makes the structure easier, but do not cancel terms illegally across addition.
4. Tangents and normals
At x = a, tangent gradient is f'(a). The normal is perpendicular, so its gradient is the negative reciprocal when the tangent gradient is non-zero and finite.
Find the point (a, f(a)) from the original function, then form the line through that point. A horizontal tangent has a vertical normal; handle this special case directly.
5. Stationary points
A stationary point satisfies f'(x) = 0. Solve for x, find y and classify it. A sign change from positive to negative derivative gives a local maximum; negative to positive gives a local minimum.
Alternatively, if f''(a) < 0 the stationary point is a local maximum, and if f''(a) > 0 it is a local minimum. If f''(a) = 0, this test is inconclusive. Points of inflexion are excluded, so do not invent them as an assessed classification.
Full justification of maximum or minimum conclusions is expected.
6. Connected rates of change
If variables depend on time, connect their rates using the chain rule. For V as a function of r and r as a function of t:
dV/dt = dV/dr × dr/dt.
Write units and signs. A decreasing radius has negative dr/dt. Ensure every quantity is evaluated at the same stated instant.
7. Small increments and approximations
For a small change δx:
δy ≈ dy/dx × δx.
Thus f(x + δx) ≈ f(x) + f'(x)δx. This local linear approximation improves as δx becomes small. It is not exact unless the function is linear.
Use absolute differentials for approximate error magnitude and relative or percentage error only after dividing by the relevant quantity.
8. Optimisation
Translate the practical condition into one objective function of one variable. State its physical domain, differentiate, solve f'(x) = 0 and justify maximum or minimum with a derivative test or valid endpoint comparison.
Report the requested quantity, which may be the dimensions and the optimal area or volume. A stationary point outside the physical domain is irrelevant, and a closed finite domain may have its optimum at an endpoint.
9. Integration as reverse differentiation
An indefinite integral represents a family of antiderivatives and must include an arbitrary constant C. Integrate powers by increasing the exponent by one and dividing by the new exponent, except for x⁻¹, whose integral is ln|x|.
The syllabus includes 1/x and 1/(ax + b), powers (ax + b)ⁿ for rational n including n = -1, sin(ax + b), cos(ax + b), sec²(ax + b) and eax+b. Divide by the inner linear coefficient as the reverse chain factor.
Trigonometric integration uses radians.
10. Initial and boundary conditions
Use a known point or initial value to determine C after integrating. Do not set C = 0 without evidence.
Different antiderivatives can look different but should simplify to expressions differing only by a constant. Differentiate the result to check both the functional form and inner coefficient.
11. Definite integrals and plane areas
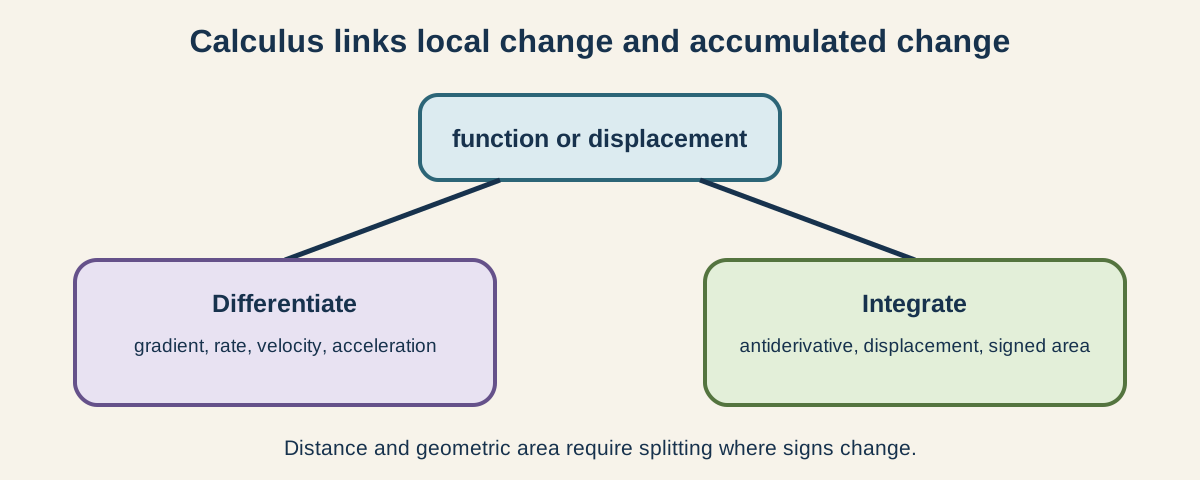
A definite integral gives signed area relative to the x-axis. For geometric area, split at roots or intersection points so regions below the axis contribute positively after taking magnitude.
For area between curves, integrate upper minus lower over each interval. Cambridge includes line-curve areas, two-curve areas and sums of two areas. Find exact intersection limits first.
Sketching the region prevents reversing the curves or omitting a sign change.
12. Straight-line kinematics
For displacement s, velocity v and acceleration a:
v = ds/dt, a = dv/dt = d²s/dt².
Integrating acceleration gives velocity plus a constant; integrating velocity gives displacement plus a constant. Initial conditions determine those constants.
A particle is instantaneously at rest where v = 0. It changes direction when velocity changes sign, not merely whenever acceleration is zero.
13. Displacement and total distance
Displacement over an interval is the signed integral of velocity, or final position minus initial position. Total distance adds absolute travel and must split the time interval wherever velocity changes sign.
Speed is |v|. A speed-time graph stays on or above the axis, whereas a velocity-time graph may be negative.
14. Motion graphs
The syllabus requires drawing and using displacement-time, distance-time, velocity-time, speed-time and acceleration-time graphs. Gradient of displacement-time is velocity; gradient of distance-time is speed; gradient of velocity-time is acceleration.
Area under velocity-time gives displacement. Area under speed-time gives distance. Turning points on a displacement-time graph correspond to zero velocity, while a distance-time graph cannot decrease.
15. Boundary controls
No calculus formula is supplied in the examination list, so derivative and integral rules must be recalled. First-principles technique is not required, though the limit concept is understood informally. Points of inflexion are not included in stationary-point work.
Keep functions inside their domains: ln x needs x > 0, rational expressions exclude zero denominators, and rational powers may carry real-domain restrictions.
Worked example: displacement versus distance
A particle has velocity v = 3t² - 12t + 9 for 0 ≤ t ≤ 4. Factor v = 3(t - 1)(t - 3), so the particle changes direction at t = 1 and t = 3. An antiderivative is F(t) = t³ - 6t² + 9t. The displacement is F(4) - F(0) = 64 - 96 + 36 = 4 metres. For total distance, split at direction changes: |F(1) - F(0)| + |F(3) - F(1)| + |F(4) - F(3)| = |4| + |0 - 4| + |4 - 0| = 12 metres. The particle ends 4 metres forward but travels 12 metres because the negative-velocity interval contributes positive distance.
Common misconceptions and how to correct them
Using degree mode for trigonometric calculus. Differentiation and integration require radians.
Omitting the inner derivative in a chain rule. Multiply by it.
Reversing quotient-rule terms. Use u'v - uv'.
Using the x-coordinate instead of the point in a tangent equation. Calculate f(a).
Treating every stationary point as a maximum. Apply a first or second derivative test.
Calling f'' = 0 a point of inflexion. The test is inconclusive and inflexions are excluded.
Dropping a negative sign in a related rate. Direction of change matters.
Treating δy ≈ f'(x)δx as exact. It is a local approximation.
Optimising before reducing to one variable. Apply the constraint first.
Omitting C in an indefinite integral. Include the arbitrary constant.
Using the power rule on x⁻¹. Its integral is logarithmic.
Calling a definite integral below the axis positive area. It is signed.
Integrating lower minus upper for area between curves. Use upper minus lower.
Equating acceleration zero with a change of direction. Direction depends on velocity sign.
Using displacement as total distance. Split where velocity changes sign.
Drawing a decreasing distance-time graph. Total distance cannot decrease.
Assessment guidance
Write the differentiation or integration rule and preserve radian mode for trigonometric functions. Tangent and normal answers need the point and correct gradient. Stationary-point classifications require a first-derivative sign change, a decisive second derivative or another fully justified method. In related rates, connect variables before inserting the instant and state units. Indefinite integrals require C; definite area requires a sketch, intersection limits and sign control. In kinematics, distinguish vector-like displacement and velocity from scalar distance and speed, split at every velocity sign change, and connect graph gradients or areas to the correct physical quantity. Do not use first principles or inflexion classification as substituted syllabus ownership.
Retrieval practice
Differentiate powers, composites, products, quotients, trigonometric, exponential and logarithmic functions. Find tangents, normals and fully classified stationary points. Solve one connected-rate and one small-increment problem, then optimise a constrained shape with endpoint checks. Integrate every listed function family, determine constants, calculate areas across sign changes and solve a particle problem using all five required motion graphs, displacement and total distance.