This guide practises determining sound speed using phase positions or pulse arrival times. The outline is a starting point for a locally approved method and risk assessment, not a complete validated procedure. Check the current Pearson specification and practical guide for course-specific requirements.
Aim and scientific principle
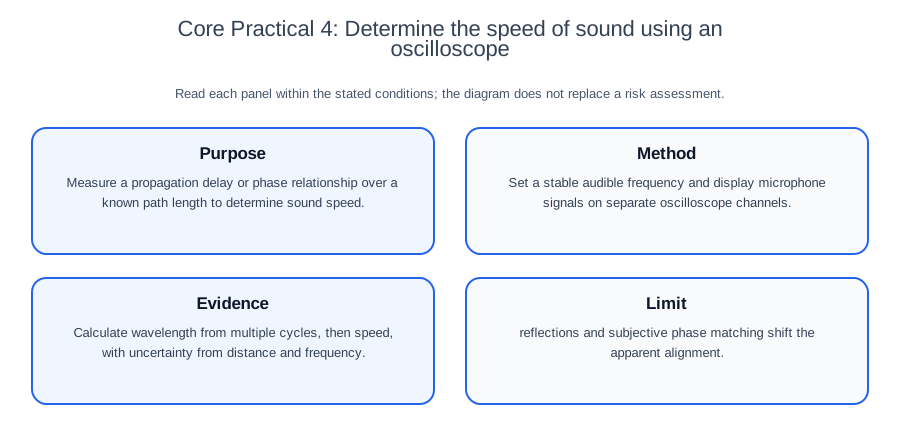
Determine sound speed either from wavelength and frequency in a progressive-wave phase method, or from the arrival-time difference of an identifiable pulse over a known acoustic path difference. State which method is used; a periodic phase shift alone does not identify the total travel time.
Begin by translating the title into a testable question. Identify what is deliberately changed, what is measured directly, what is calculated and what must remain controlled. Predict a relationship only after naming the mechanism. A prediction without a reason is weak; a reason without measurable variables cannot guide a practical design.
Apparatus and setup
Use signal generator, loudspeaker, two microphones, oscilloscope, metre rule and stands. Consider measuring range, resolution, uncertainty, calibration and suitability for the sample, not the instrument name alone. Draw a labelled scientific setup that shows the working geometry and exactly where readings are taken. Include a control or blank when it distinguishes the target effect from drift, contamination or background response.
Before collecting results, check zero readings, calibration, leaks, alignment or sterility as relevant. Record the instrument resolution beside the first raw-data table. If a digital device displays more digits than its underlying accuracy supports, do not treat every digit as equally certain.
Method
For the phase method, set a stable frequency and display the two microphone signals on separate oscilloscope channels. Keep one microphone fixed and move the other along the direct propagation direction, maintaining orientation and reducing reflections.
Track successive returns to the same phase alignment without skipping cycles. Record positions spanning N full wavelength intervals, which requires N + 1 alignment positions. Measure the total displacement D, then use λ=D/N
Check this topic from memory
Attempt the matching topic bank before reopening the notes. Use each missed idea to decide what to review next.
. Several intervals reduce fractional endpoint uncertainty only when cycle counting and geometry remain valid.
For time of flight, use an identifiable pulse or suitable non-repeating signal and compare the same direct arrival on synchronously acquired microphone channels. Measure the difference in source-to-microphone path lengths, not an arbitrary separation. Check channel timing offsets and reflected arrivals before dividing path difference by delay.
Repeat at several path differences or repeat the phase-position sequence. For time of flight, fitting arrival-time difference against path difference can separate a constant channel delay from the propagation gradient. If investigating frequency, repeat a complete wavelength determination at each frequency and check frequency-dependent channel response rather than claiming frequency was held constant.
Plan the analysis before starting. This reveals whether an additional measurement is needed for a derived quantity and prevents a completed experiment from lacking a mass, length, concentration, background or calibration value. A method should be detailed enough for another trained student to reproduce, while avoiding decorative steps that do not affect validity.
Variables and controls
Independent variable: microphone position or acoustic path difference for the chosen method; alternatively, a planned frequency series with a separate wavelength determination at each frequency.
Dependent variable: positions of repeated phase alignments, or the delay between matching direct pulse arrivals; wavelength and speed are calculated quantities.
Important controls: air conditions, propagation geometry, microphone orientation, reflections and acquisition settings; hold frequency stable within each phase-position sequence and characterise relevant channel offsets.
For each control, state how it is maintained or monitored. Simply writing "keep temperature constant" is incomplete if the method has no bath, probe, equilibration time or other means of doing so. Choose a range wide enough to reveal the relationship but within safe and scientifically valid limits. Choose the number, range and spacing of values for the expected response and analysis. Concentrating values near an uncertain threshold or optimum can be more useful than uniform spacing; no fixed count establishes an adequate design.
What is distinctive about this practical
In a progressive wave at fixed frequency, successive returns to the same phase correspond to one wavelength of path change, provided geometry and channel response remain stable. The wave-speed relation is v=fλ. An absolute sine-wave phase comparison gives delay only modulo its period T=1/f: delays Δt+nT, for integer n, have the same phase. It is therefore unsafe to interpret one apparent sine-wave offset as the complete travel time.
In a pulse method, identify the same direct feature at both microphones and distinguish it from echoes. A simple measurement model is Δtm=Δd/v+τ, where subscript m denotes the measured delay, the acoustic path difference is measured, and the channel offset is constant over the fitted series. The delay-versus-path gradient is the reciprocal of speed; the intercept estimates that constant offset. Variable channel delay, changed geometry or misidentified arrivals invalidate this interpretation. A correlation algorithm applied to a repeating sine wave still has whole-cycle ambiguity.
Recording and processing results
For phase measurements, record alignment positions and interval indices, distinguish intervals from positions, and calculate wavelength and speed with distance and frequency uncertainties. For pulse measurements, record acoustic path differences, arrival criteria, delays and timing uncertainty; interpret the gradient only under the stated offset model. Keep phase and pulse datasets separate. Put units in column headings, record raw readings consistently with instrument resolution and the method and distinguish repeats from calculated means. Do not delete an anomaly merely because it is inconvenient. Recheck the condition, look for a procedural explanation and state any exclusion rule.
Choose a fitted line, curve or ruled joins according to the data, scientific relationship and question; do not connect or smooth points mechanically. A gradient should use a large triangle and values read from the fitted line. When a relationship is linearised, explain the transformation and connect gradient or intercept to the requested physical quantity. When observations are categorical, define the category rule before seeing the result.
Safety, ethics and responsible practice
Use moderate sound levels, secure stands and route leads to avoid trips. A useful safety statement names the hazard, identifies who or what could be harmed and gives a control that reduces likelihood or severity. "Take care" does not specify an action that reduces the identified risk.
Worked application: from raw evidence to a defensible conclusion
As a counting check rather than measured data, six successive alignment positions contain five full wavelength intervals. Divide the endpoint displacement by five, not six. Dividing by the number of positions would underestimate wavelength, and therefore speed at fixed frequency, by the factor 5/6. This check does not verify the phase matches, path geometry or frequency calibration.
For actual data, retain the full phase-position sequence or synchronised pulse records. Check repeatability, direct-path identification, reflections and relevant channel offsets before choosing a mean or fit. Do not use a periodic sine-wave correlation peak as proof of an unambiguous propagation time. Retain original observations and justify exclusions.
This chain is stronger than a memorised recipe because every step answers the practical question. If the graph contradicts the prediction, report the evidence honestly and investigate method, range, controls and model assumptions before claiming a new scientific law.
Evaluation: limitation, effect and improvement
Limitation: reflections and subjective phase matching shift the apparent alignment.
Likely effect: reflections can create a different apparent phase match, shifting the measured wavelength by part or all of a cycle. Subjective matching adds scatter to microphone-position readings.
Targeted improvement: reduce reflections, preserve direct-path geometry and track several phase intervals with explicit cycle counts. Digital phase measurement can improve matching but cannot remove whole-cycle ambiguity. For time of flight, use identifiable pulses or suitable non-repeating signals, synchronous channels and an appropriate offset check; cross-correlation is not an automatic correction for echoes or channel latency.
Separate random variation, systematic bias and model limitation. Repeats help reveal random variation but do not remove a zero error. Calibration establishes the relation between reference values and indications; appropriate adjustment or correction can address an identified offset. It does not make biased sampling representative. Finer resolution and greater repeatability are distinct properties, and finer resolution may improve an estimate only when the reading is a material source of uncertainty.
Common misconceptions and corrections
Repeats automatically make a result accurate. Repeats estimate random variation; they do not correct a biased method or calibration error.
A control variable is just a list item. Explain the apparatus or procedure that keeps it stable.
The line must pass through every point. Use the overall pattern and a best-fit relationship, then investigate justified anomalies.
Percentage error and percentage uncertainty are interchangeable. Error compares a measured value with a suitable reference. Uncertainty characterises dispersion of values attributed to the measurand; it may be expressed as a standard uncertainty or an interval with stated coverage, and includes more than resolution alone. State the reference, denominator and uncertainty convention used.
A successful endpoint proves the theory. The observation supports a conclusion only within the method, range and assumptions tested.
More sophisticated apparatus is always better. The improvement must address the dominant limitation and be practical in the stated context.
Assessment guidance
Pearson states that IAL practical skills are assessed mainly in Unit 3 and Unit 6, with related theory also assessable in the other unit papers. Planning answers need an operational independent variable, a measured dependent variable, a justified range, controls, repeats, safety and a stated analysis. Data answers need units, consistent precision, sensible significant figures and transparent calculations. Graph answers need labelled axes, a scale using the grid well and line treatment appropriate to the data and question. Evaluation answers should use a limitation-effect-improvement chain specific to the apparatus. Do not claim that a memorised core-practical recipe is the only acceptable method when the question supplies a different valid context.
Retrieval practice
Extend or adapt this practical to answer a related question. Where the design uses a continuous variable, justify its planned values. List apparatus with range and resolution where relevant, control methods, a raw record layout, the expected analysis and one hazard-control pair. Then identify one random uncertainty, one systematic bias and one model limitation. Explain which can be reduced by repeats, which needs calibration followed by appropriate correction or adjustment, or a redesign, and how your conclusion would change if the anomaly were confirmed.